
Built by Paweł ‘Pawelos’ Laszczak
2024 MultiGP Drone Racing World Champion, and the pilot behind FPV PID Tune.
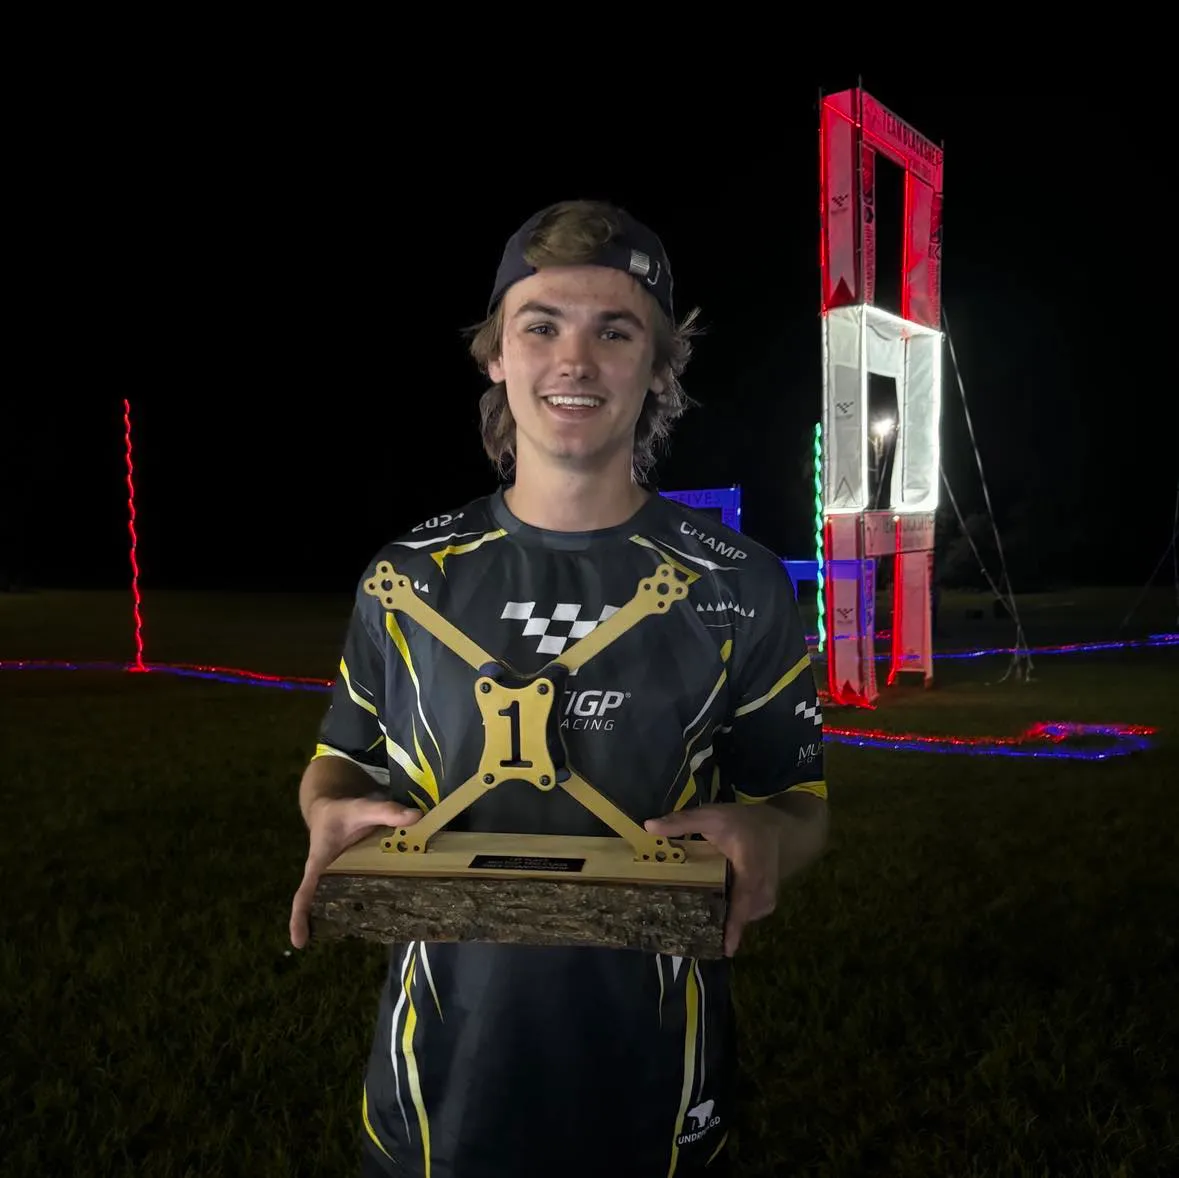
Paweł built his first drone in 2016 as a school project. He taught himself to solder and flash firmware, was racing within a year, and won his first international race in 2018.
The record
- 2024MultiGP Drone Racing World Champion
- 2022Silver medal, The World Games, Birmingham
- 2018 to 2023Four FAI Drone Racing World Cup season-ranking medals: silver in 2018, 2019 and 2023, bronze in 2021
- 2019, 2022, 2023Champion of Poland, three times
- 2023First Polish pilot in the Drone Racing League (DRL), in the 2023 rookie season
Why I built FPV PID Tune
I have spent years tuning my own quads, and a good tune takes a lot of flights and a lot of guessing. FPV PID Tune is the tool I wanted: plug in over USB, fly four packs, and get exact PID and filter values measured from your own flight logs.
I also built it for pilots with more than one quad. Two copies of the same build rarely fly quite alike: motors from a different batch, a frame that resonates at a different frequency, a slightly heavier camera. Pasting one tune onto every quad doesn’t fix that. FPV PID Tune tunes each quad from its own flight, so pick the same feel on each and your whole fleet flies the same way, whichever one you grab.
Your tune doesn’t change until you press Apply, your original settings are backed up first, and one click puts them back. I built it so more pilots can spend their time flying instead of fiddling.
Find Paweł elsewhere
Try it on your quad.
Your tune doesn’t change until you press Apply.
Tuning runs on a computer, with your quad on USB. Here you can try the free log check.